How an Exoskeleton Joint Moves with a Motor, Screw, and Linkage
This patent describes a compact and efficient way to make an exoskeleton joint bend and straighten using a motor, a special screw, and a clever set of levers.
Original patent title: “Actuator devices for human exoskeleton joints”
This patent describes a compact and efficient way to make an exoskeleton joint bend and straighten using a motor, a special screw, and a clever set of levers. Granted to Ekso Bionics in 2023 with 17 claims and 1 forward citation, and it is expected to expire in 2038.
Coverage
What does this patent actually cover?
This patent details an actuator mechanism for an exoskeleton joint. It connects a first support (like a thigh brace) and a second support (like a shin brace) to a wearer. The actuator uses a motor (claimclaimA numbered sentence at the end of a patent that legally defines what the inventor owns. The most important section.Read more → 1) that spins a 'ball screw' (claim 1). This screw then moves a 'ball nut' along its length, which in turn pushes or pulls a 'yoke' (claim 1). The yoke is designed to move only in a straight line, acting like a slider (claim 1). This straight-line motion of the yoke then pushes or pulls a 'linkage,' which is a rod or bar (claim 1). Finally, the linkage causes a 'joint crank' to rotate around the exoskeleton's main joint (claim 1), making the two supports move relative to each other, like bending a knee. For example, as the motor spins, the yoke slides, pushing the linkage, which rotates the joint crank to bend the exoskeleton's knee joint.
The gap
What does this patent NOT cover?
- Does not cover exoskeleton joints that use direct rotary motors without a ball screw and linkage system.
- Does not cover actuators where the yoke rotates or moves in a non-linear fashion, as it specifies the yoke moves 'only in translation' (claimclaimA numbered sentence at the end of a patent that legally defines what the inventor owns. The most important section.Read more → 1).
- Does not cover systems where the motor, ball screw, ball nut, and yoke are not arranged collinearly (claimclaimA numbered sentence at the end of a patent that legally defines what the inventor owns. The most important section.Read more → 1).
- Does not cover actuators that rely on hydraulic or pneumatic cylinders instead of a motor and ball screw mechanism.
- Does not cover a roller and joint cam system, as described in the abstractabstractA short summary at the front of the patent describing the invention. Not legally binding.Read more →, if it does not also include the linkage and joint crank as claimed (claimclaimA numbered sentence at the end of a patent that legally defines what the inventor owns. The most important section.Read more → 1).
These exclusions are unique to PatentBrief — derived from the actual claim language, not patent-office boilerplate.
Key facts
What made this novel
The noveltynoveltyThe requirement that an invention be different from anything publicly known before its priority date.Read more → lies in the specific combination and arrangement of components: using a ball screw to translate a yoke, which then acts as a slider to drive a linkage and joint crank. This efficiently converts linear motion into powerful rotational motion at the joint, while constraining the yoke to pure translation for reliability.
The Patent Drawing
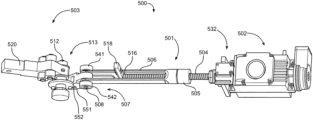
Schematic visualization of the patent's claim structure. Hand-drawn diagrams in progress for each landmark patent.
Where you've seen this
Real-world examples
Ekso Bionics EksoNR exoskeleton
Powered prosthetic limbs
Industrial assist exoskeletons
Robotic rehabilitation devices
Why it matters
The bigger picture
Exoskeletons need powerful yet precise ways to move their joints to help people walk or lift heavy objects. This patent focuses on a specific mechanical design for these actuators, aiming for efficiency and control. The design elements, such as the ball screw and linkage, are critical for translating a motor's rotation into the strong, controlled bending and straightening motions required for human assistance or augmentation.
Filed
March 7, 2018
Granted
June 13, 2023
Market context
Who's building on this
Companies in this space
Ekso Bionics Inc., the assigneeassigneeThe entity that owns the patent — usually the inventor's employer or a company.Read more →, is actively developing and selling medical exoskeletons for rehabilitation and industrial use. Other companies in the powered exoskeleton space, such as ReWalk Robotics, Sarcos Technology and Robotics Corporation, and Cyberdyne, are also continually innovating in joint actuation mechanisms, though their specific designs may vary.
Market impact
This patent contributes to the ongoing development of more effective and compact actuators for exoskeletons. Such advancements enable lighter, more powerful, and more natural-feeling devices, expanding their use in medical rehabilitation, industrial assistance, and potentially military applications. It helps refine the mechanical solutions available for converting motor power into functional joint movement in wearable robotics.
Claim 1 — Plain English
What this patent covers
This patent details an actuator mechanism for an exoskeleton joint. It connects a first support (like a thigh brace) and a second support (like a shin brace) to a wearer. The actuator uses a motor (claim 1) that spins a 'ball screw' (claim 1). This screw then moves a 'ball nut' along its length, which in turn pushes or pulls a 'yoke' (claim 1). The yoke is designed to move only in a straight line, acting like a slider (claim 1). This straight-line motion of the yoke then pushes or pulls a 'linkage,' which is a rod or bar (claim 1). Finally, the linkage causes a 'joint crank' to rotate around the exoskeleton's main joint (claim 1), making the two supports move relative to each other, like bending a knee. For example, as the motor spins, the yoke slides, pushing the linkage, which rotates the joint crank to bend the exoskeleton's knee joint.
The clever bit
The novelty lies in the specific combination and arrangement of components: using a ball screw to translate a yoke, which then acts as a slider to drive a linkage and joint crank. This efficiently converts linear motion into powerful rotational motion at the joint, while constraining the yoke to pure translation for reliability.
What it does not cover
- Does not cover exoskeleton joints that use direct rotary motors without a ball screw and linkage system.
- Does not cover actuators where the yoke rotates or moves in a non-linear fashion, as it specifies the yoke moves 'only in translation' (claim 1).
- Does not cover systems where the motor, ball screw, ball nut, and yoke are not arranged collinearly (claim 1).
- Does not cover actuators that rely on hydraulic or pneumatic cylinders instead of a motor and ball screw mechanism.
- Does not cover a roller and joint cam system, as described in the abstract, if it does not also include the linkage and joint crank as claimed (claim 1).
Patent timeline
Application submitted to the patent office
Application published, typically 18 months after filing
Patent officially issued
Patent enters public domain
PatentBrief Score
Impact Score
Early stage
Citation count
6/40
Early citations
Claim breadth
11/20
Broad claimsclaimsThe numbered statements at the end of a patent that legally define what the inventor owns.Read more →
Recency
20/20
Granted within 5 years
Assignee scale
0/20
Independent or smaller assigneeassigneeThe entity that owns the patent — usually the inventor's employer or a company.Read more →
PatentBrief Impact Score — based on citation count, claim breadth, recency, and assignee scale. Not a legal assessment.
Heuristic Value Estimate
What this patent might be worth
$35K – $112K
Midpoint $70K · 11.4 yr remaining · industry ×0.9
Heuristic only — blends forward/backward citation counts, claim scope, time remaining, litigation history, and CPC-derived industry baseline. Real valuations need a professional appraisal.
Claim text not yet imported for this patent
The original legal language
Original claims
17 claims as filed with the patent office.
Concepts involved
Citations
Patent lineage
Cite this patent
JULIN, A. (2023). How an Exoskeleton Joint Moves with a Motor, Screw, and Linkage (U.S. Patent No. 11,673,253). U.S. Patent and Trademark Office. https://patentbrief.org/patent/us/11673253/actuator-devices-for-human-exoskeleton-joints
Auto-generated from the patent record. Double-check author order and the issue date against the official USPTO document before submitting.
Embed
Add this patent to your site
Drop this plain-English patent card into any blog post or article — free, no signup. It always links back to the full breakdown here.
<div data-patentlens-widget data-patent-number="US11673253"></div>
<script src="https://patentbrief.org/embed.js" async></script>
Stay in the loop
Get a weekly digest of new patents.
One email per week. No spam. Unsubscribe anytime.
Keep exploring
Related patents you should know
US 4683195 · 1987
How to Make Billions of Copies of a DNA Segment
This patent describes the Polymerase Chain Reaction (PCR), a method to rapidly create many copies of a specific piece of DNA or RNA, enabling its detection and analysis.
Cetus Corp
US 8697359 · 2014
How to Edit Genes in Human Cells Using an Engineered CRISPR System
This patent describes an engineered CRISPR-Cas9 system for precisely cutting DNA in eukaryotic cells to change how genes work, opening the door for gene editing in complex organisms.
Massachusetts Institute of Technology
US 7657849 · 2010
How the iPhone's Slide-to-Unlock Gesture Works
Apple's 2010 patent describes unlocking a device by dragging a specific graphical image across the touchscreen along a predefined path, a gesture that became iconic with the original iPhone.
Apple Inc
US 4733665 · 1988
How Doctors Implant a Permanent Stent Using a Balloon
This patent describes the method for placing a permanent, expandable wire mesh tube inside a blood vessel or other body tube using a balloon-tipped catheter to widen it and keep it open.
Expandable Grafts Partnership
US 4965188 · 1990
How to Make Many Copies of a DNA Piece with Heat
This patent describes the Polymerase Chain Reaction (PCR) method, a technique to make millions of copies of a specific DNA segment using a heat-resistant enzyme and repeated temperature changes.
Cetus Corp
US 4235871 · 1980
How to Encapsulate Active Materials in Lipid Bubbles Efficiently
This patent describes a method for trapping biologically active substances inside tiny, multi-layered fat bubbles called liposomes, using a specific water-in-oil emulsion and gel-forming process to improve how much material gets captured.
Individual
Semantically similar
You might also find these interesting
US 10702441 · 2020 · Ekso Bionics
How Exoskeletons Use Screws and Cables to Move Joints
US 11304827 · 2022 · Dephy
Flexible Footplate for Robotic Walking Assistance
US 10800031 · 2020 · Arizona State University Downtown Phoenix campus
How a Robotic Exoskeleton Helps Your Shoulder Move
US 10814473 · 2020 · Arizona State University Downtown Phoenix campus
Exoskeleton Shoulder Joint That Adapts to Your Arm's Movement
More to explore
More in AI & Machine Learning
US 10452978 · 2019 · Google LLC
How AI Models Understand Language Using 'Attention'
US 6523026 · 2003 · Huntsman International LLC
How Computers Find Hidden Connections Between Different Fields of Knowledge
US 11615208 · 2023 · Capital One Services LLC
How Cloud Systems Automatically Create and Train AI Data Models
US 10402750 · 2019 · Facebook Inc
How Facebook Uses Deep Learning to Predict What You Might Like
New to patents?
Common Questions
Frequently Asked Questions
What does How an Exoskeleton Joint Moves with a Motor, Screw, and Linkage cover?
This patent describes a compact and efficient way to make an exoskeleton joint bend and straighten using a motor, a special screw, and a clever set of levers.
Who owns patent US 11673253?
Ekso Bionics owns this patent, granted in 2023.
When does this patent expire?
This patent is expected to expire on March 7, 2038, when the invention enters the public domain.
What is patent US 11673253 cited by?
This patent has been cited by 1 later patents that build on its ideas.
What problem does this patent solve?
Exoskeletons need powerful yet precise ways to move their joints to help people walk or lift heavy objects. This patent focuses on a specific mechanical design for these actuators, aiming for efficiency and control. The design elements, such as the ball screw and linkage, are critical for translating a motor's rotation into the strong, controlled bending and straightening motions required for human assistance or augmentation.
What does this patent NOT cover?
Does not cover exoskeleton joints that use direct rotary motors without a ball screw and linkage system.
Same assignee
More from Ekso Bionics
Patent monitoring