Robot Design for Carrying Objects While Walking
This patent describes a robot with a torso, legs, arms, and a special forward-extending protrusion designed to help it carry objects while it walks.
Original patent title: “Torso protrusion for robotic manipulation of objects and related technology”
This patent describes a robot with a torso, legs, arms, and a special forward-extending protrusion designed to help it carry objects while it walks. Granted to Agility Robotics in 2025 with 23 claims and 3 forward citations, and it is expected to expire in 2042.
Coverage
What does this patent actually cover?
This patent details a robot designed to carry objects while moving. The robot has a torso with upper and lower sections, legs attached to the lower torso for walking, and arms attached to the upper torso. The key feature is a protrusion extending forward from the lower part of the torso. The robot uses its arms to bring an object closer to its body. While walking, it supports the object's weight using this protrusion. Importantly, the protrusion can move upwards relative to the torso as the robot walks, helping to stabilize the carried object.
The gap
What does this patent NOT cover?
- Robots that do not have a torso with superior, inferior, and intermediate portions.
- Robots that cannot ambulate (walk) using legs.
- Robots that cannot move an object toward the torso using arms.
- Robots that do not have a protrusion extending anteriorly from the torso.
- Robots that cannot support an object's weight using the protrusion while ambulating.
- Robots where the protrusion cannot move superiorly relative to the torso while supporting weight.
These exclusions are unique to PatentBrief — derived from the actual claim language, not patent-office boilerplate.
Key facts
What made this novel
The innovation lies in the protrusion's ability to move superiorly relative to the torso while the robot is walking and supporting an object. This dynamic support mechanism likely helps maintain balance and stability by adjusting to the robot's gait and the object's weight distribution.
The Patent Drawing
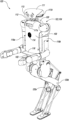
Schematic visualization of the patent's claim structure. Hand-drawn diagrams in progress for each landmark patent.
Where you've seen this
Real-world examples
Agility Robotics' Digit robot
Why it matters
The bigger picture
This patent is relevant to the development of humanoid robots capable of complex tasks in dynamic environments, such as logistics and manufacturing. Robots like those from Agility Robotics are designed to operate in spaces built for humans, requiring sophisticated balance and manipulation capabilities.
Filed
December 5, 2022
Granted
March 11, 2025
Market context
Who's building on this
Companies in this space
Agility Robotics Inc., the assigneeassigneeThe entity that owns the patent — usually the inventor's employer or a company.Read more → and likely developer of the technology, is actively producing and deploying robots like Digit that embody these principles. Other companies in the advanced robotics and logistics automation sectors are also exploring similar bipedal robot designs.
Market impact
This patent contributes to the growing field of bipedal robotics for industrial applications. It aims to enable robots to perform tasks previously requiring human dexterity and mobility, potentially transforming warehouse operations, delivery services, and manufacturing assembly lines.
Claim 1 — Plain English
What this patent covers
This patent details a robot designed to carry objects while moving. The robot has a torso with upper and lower sections, legs attached to the lower torso for walking, and arms attached to the upper torso. The key feature is a protrusion extending forward from the lower part of the torso. The robot uses its arms to bring an object closer to its body. While walking, it supports the object's weight using this protrusion. Importantly, the protrusion can move upwards relative to the torso as the robot walks, helping to stabilize the carried object.
The clever bit
The innovation lies in the protrusion's ability to move superiorly relative to the torso while the robot is walking and supporting an object. This dynamic support mechanism likely helps maintain balance and stability by adjusting to the robot's gait and the object's weight distribution.
What it does not cover
- Robots that do not have a torso with superior, inferior, and intermediate portions.
- Robots that cannot ambulate (walk) using legs.
- Robots that cannot move an object toward the torso using arms.
- Robots that do not have a protrusion extending anteriorly from the torso.
- Robots that cannot support an object's weight using the protrusion while ambulating.
- Robots where the protrusion cannot move superiorly relative to the torso while supporting weight.
Patent timeline
Application submitted to the patent office
Application published, typically 18 months after filing
Patent officially issued
Patent enters public domain
PatentBrief Score
Impact Score
Moderate
Citation count
12/40
Early citations
Claim breadth
15/20
Broad claimsclaimsThe numbered statements at the end of a patent that legally define what the inventor owns.Read more →
Recency
20/20
Granted within 5 years
Assignee scale
0/20
Independent or smaller assigneeassigneeThe entity that owns the patent — usually the inventor's employer or a company.Read more →
PatentBrief Impact Score — based on citation count, claim breadth, recency, and assignee scale. Not a legal assessment.
Heuristic Value Estimate
What this patent might be worth
$42K – $135K
Midpoint $84K · 16.2 yr remaining · industry ×0.9
Heuristic only — blends forward/backward citation counts, claim scope, time remaining, litigation history, and CPC-derived industry baseline. Real valuations need a professional appraisal.
Patent Claims
0 independent claims · 1 dependent
Claims are the legal boundaries of the patent. An independent claim stands alone. A dependent claim adds limitations to its parent, narrowing — but not broadening — the scope.
The original legal language
Original claims
23 claims as filed with the patent office.
Concepts involved
Citations
Patent lineage
Cite this patent
Abate, A., & Hurst, J. (2025). Robot Design for Carrying Objects While Walking (U.S. Patent No. 12,246,441). U.S. Patent and Trademark Office. https://patentbrief.org/patent/us/12246441/torso-protrusion-for-robotic-manipulation-of-objects-and-related-technology
Auto-generated from the patent record. Double-check author order and the issue date against the official USPTO document before submitting.
Embed
Add this patent to your site
Drop this plain-English patent card into any blog post or article — free, no signup. It always links back to the full breakdown here.
<div data-patentlens-widget data-patent-number="US12246441"></div>
<script src="https://patentbrief.org/embed.js" async></script>
Stay in the loop
Get a weekly digest of new patents.
One email per week. No spam. Unsubscribe anytime.
Keep exploring
Related patents you should know
US 4683195 · 1987
How to Make Billions of Copies of a DNA Segment
This patent describes the Polymerase Chain Reaction (PCR), a method to rapidly create many copies of a specific piece of DNA or RNA, enabling its detection and analysis.
Cetus Corp
US 8697359 · 2014
How to Edit Genes in Human Cells Using an Engineered CRISPR System
This patent describes an engineered CRISPR-Cas9 system for precisely cutting DNA in eukaryotic cells to change how genes work, opening the door for gene editing in complex organisms.
Massachusetts Institute of Technology
US 7657849 · 2010
How the iPhone's Slide-to-Unlock Gesture Works
Apple's 2010 patent describes unlocking a device by dragging a specific graphical image across the touchscreen along a predefined path, a gesture that became iconic with the original iPhone.
Apple Inc
US 4733665 · 1988
How Doctors Implant a Permanent Stent Using a Balloon
This patent describes the method for placing a permanent, expandable wire mesh tube inside a blood vessel or other body tube using a balloon-tipped catheter to widen it and keep it open.
Expandable Grafts Partnership
US 4965188 · 1990
How to Make Many Copies of a DNA Piece with Heat
This patent describes the Polymerase Chain Reaction (PCR) method, a technique to make millions of copies of a specific DNA segment using a heat-resistant enzyme and repeated temperature changes.
Cetus Corp
US 4235871 · 1980
How to Encapsulate Active Materials in Lipid Bubbles Efficiently
This patent describes a method for trapping biologically active substances inside tiny, multi-layered fat bubbles called liposomes, using a specific water-in-oil emulsion and gel-forming process to improve how much material gets captured.
Individual
Semantically similar
You might also find these interesting
US 12734717 · 2026
How Humanoid Robot Actuators Connect with a Smart Wire Assembly
US 20250170731 · Boston Dynamics
How Robots Figure Out What They're Carrying While Moving
US 12736122 · 2026
Removable Protective Cap for Robot Arm Parts
US 12064197 · 2024 · Intuitive Surgical Operations
How a Robot Arm Can Be Manually Moved While Staying Safe
More to explore
More in Consumer Electronics
US 7657849 · 2010 · Apple Inc
How the iPhone's Slide-to-Unlock Gesture Works
US 7479949 · 2009 · Apple Inc
How Touchscreens Understand Your Finger Swipes and Scrolls
US 4528643 · 1985 · FPDC Inc
How Stores Make Custom Products On-Demand with Remote Approval
US 7469381 · 2008 · Apple Inc
How Touchscreens Show and Snap Back When You Scroll Past an Edge
New to patents?
Common Questions
Frequently Asked Questions
What does Robot Design for Carrying Objects While Walking cover?
This patent describes a robot with a torso, legs, arms, and a special forward-extending protrusion designed to help it carry objects while it walks.
Who owns patent US 12246441?
Agility Robotics owns this patent, granted in 2025.
When does this patent expire?
This patent is expected to expire on December 5, 2042, when the invention enters the public domain.
What is patent US 12246441 cited by?
This patent has been cited by 3 later patents that build on its ideas.
What problem does this patent solve?
This patent is relevant to the development of humanoid robots capable of complex tasks in dynamic environments, such as logistics and manufacturing. Robots like those from Agility Robotics are designed to operate in spaces built for humans, requiring sophisticated balance and manipulation capabilities.
What does this patent NOT cover?
Robots that do not have a torso with superior, inferior, and intermediate portions.
Patent monitoring